MicroMouse
Autonomous robot, built from scratch
July 2025 · IoT
- Embedded C
- PID Control
- Fusion 360
Autonomous maze-solving robot with PID control, encoder fusion, custom PCB and 3D-printed chassis.
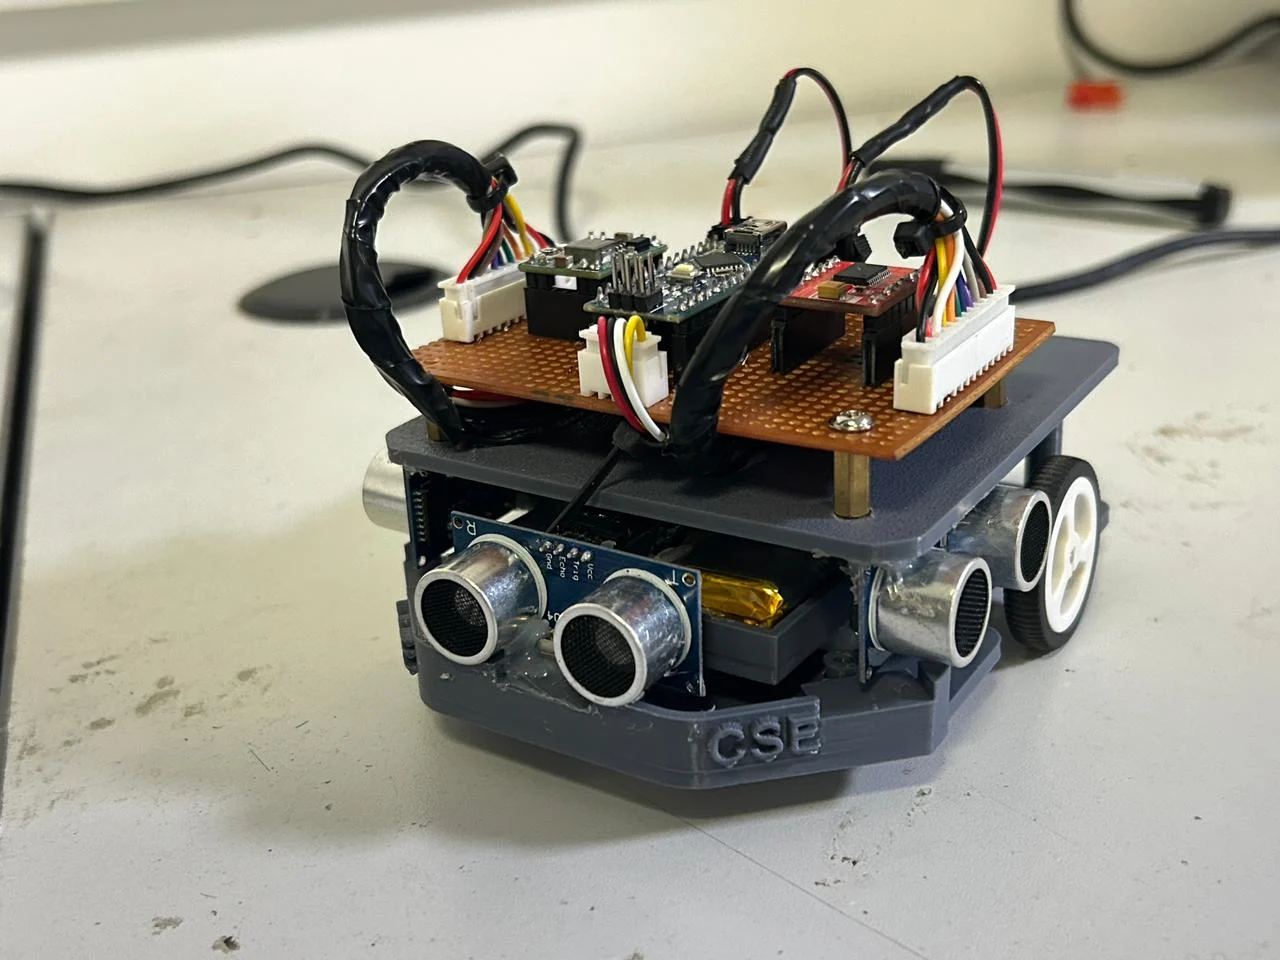
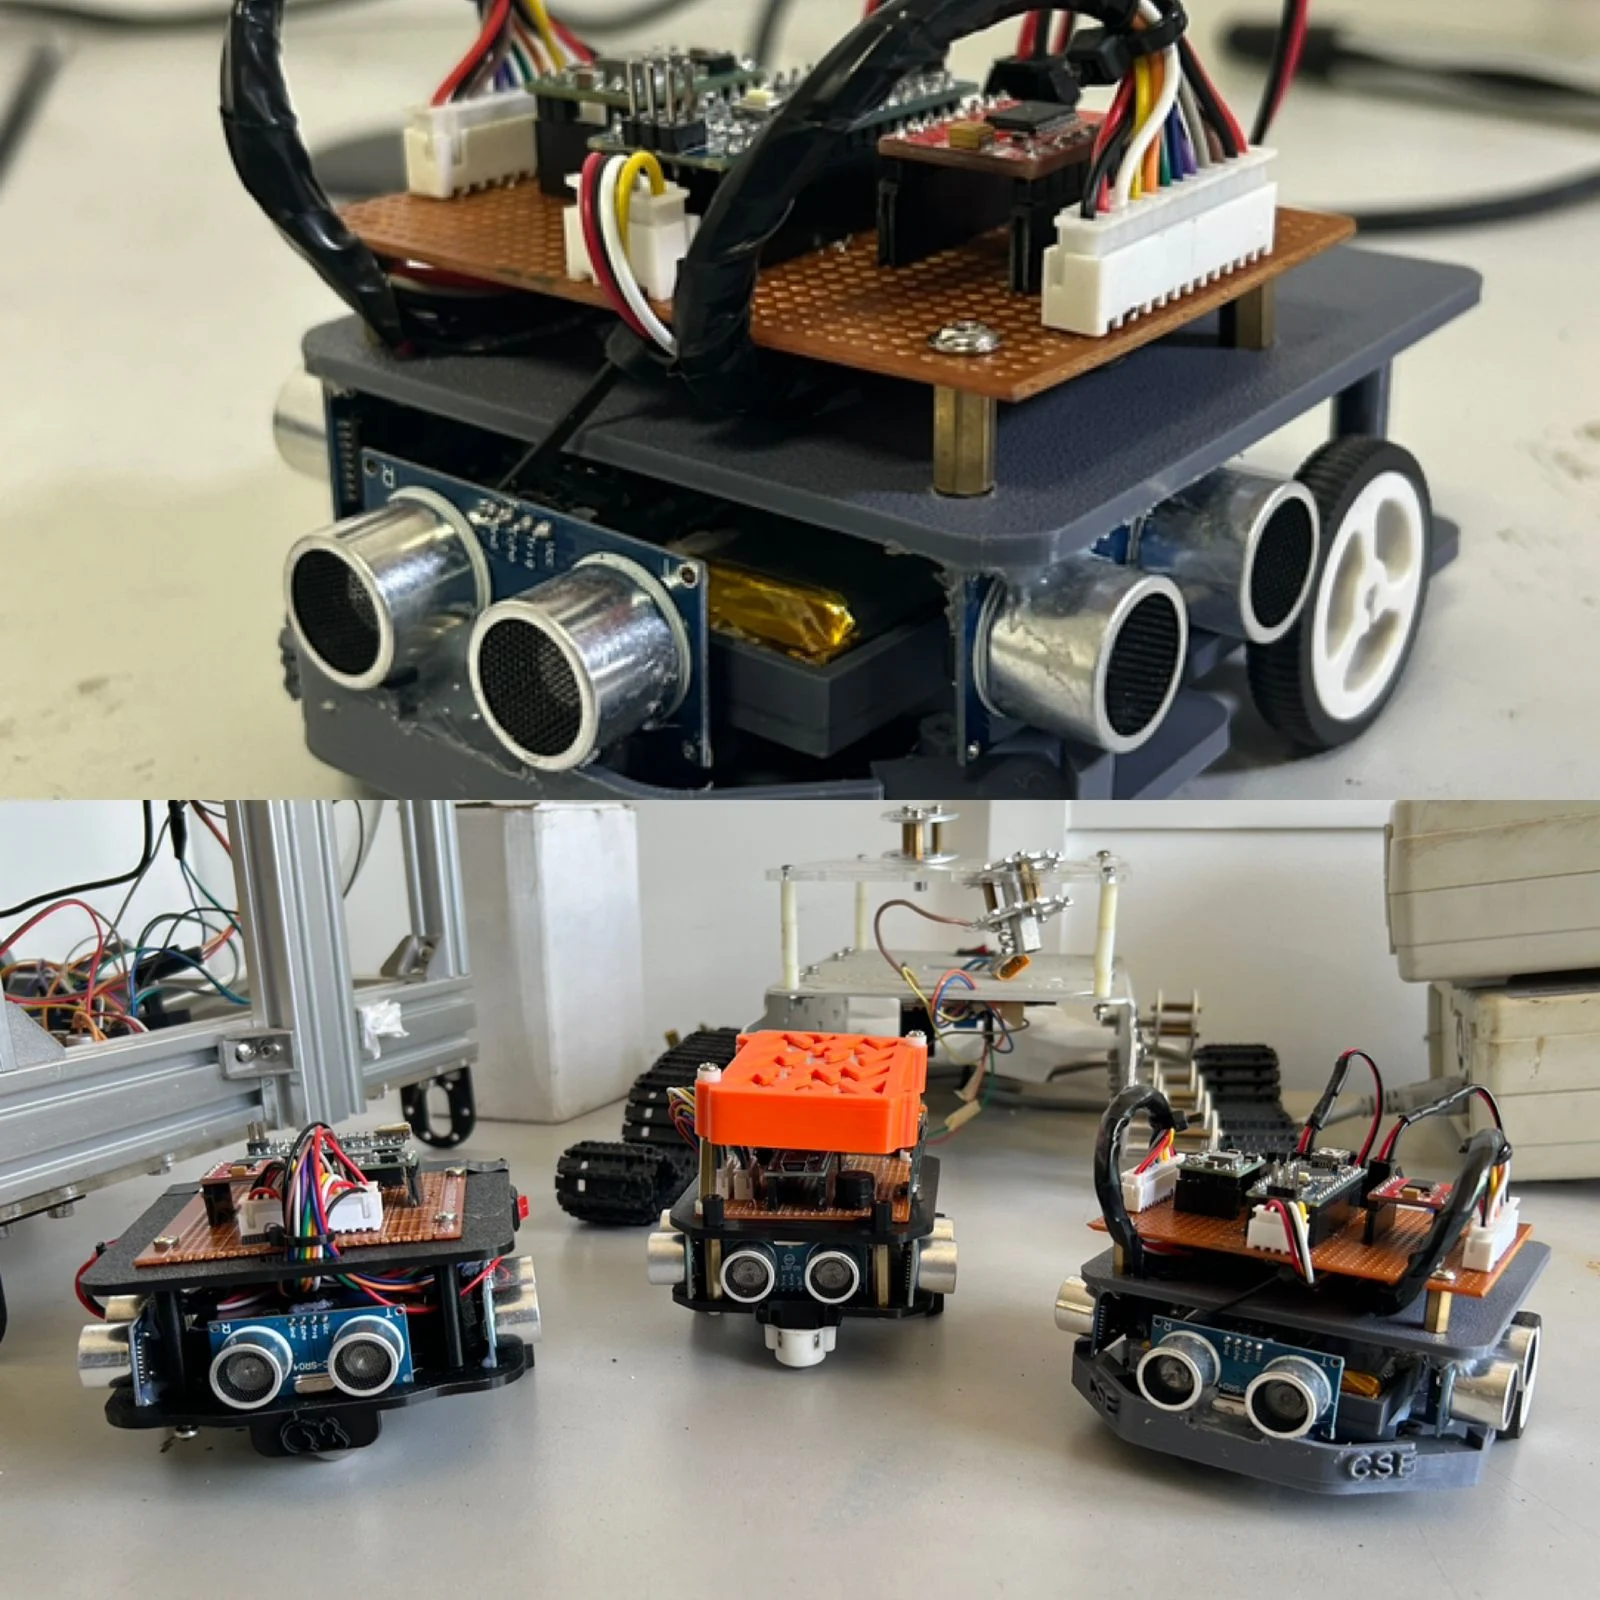
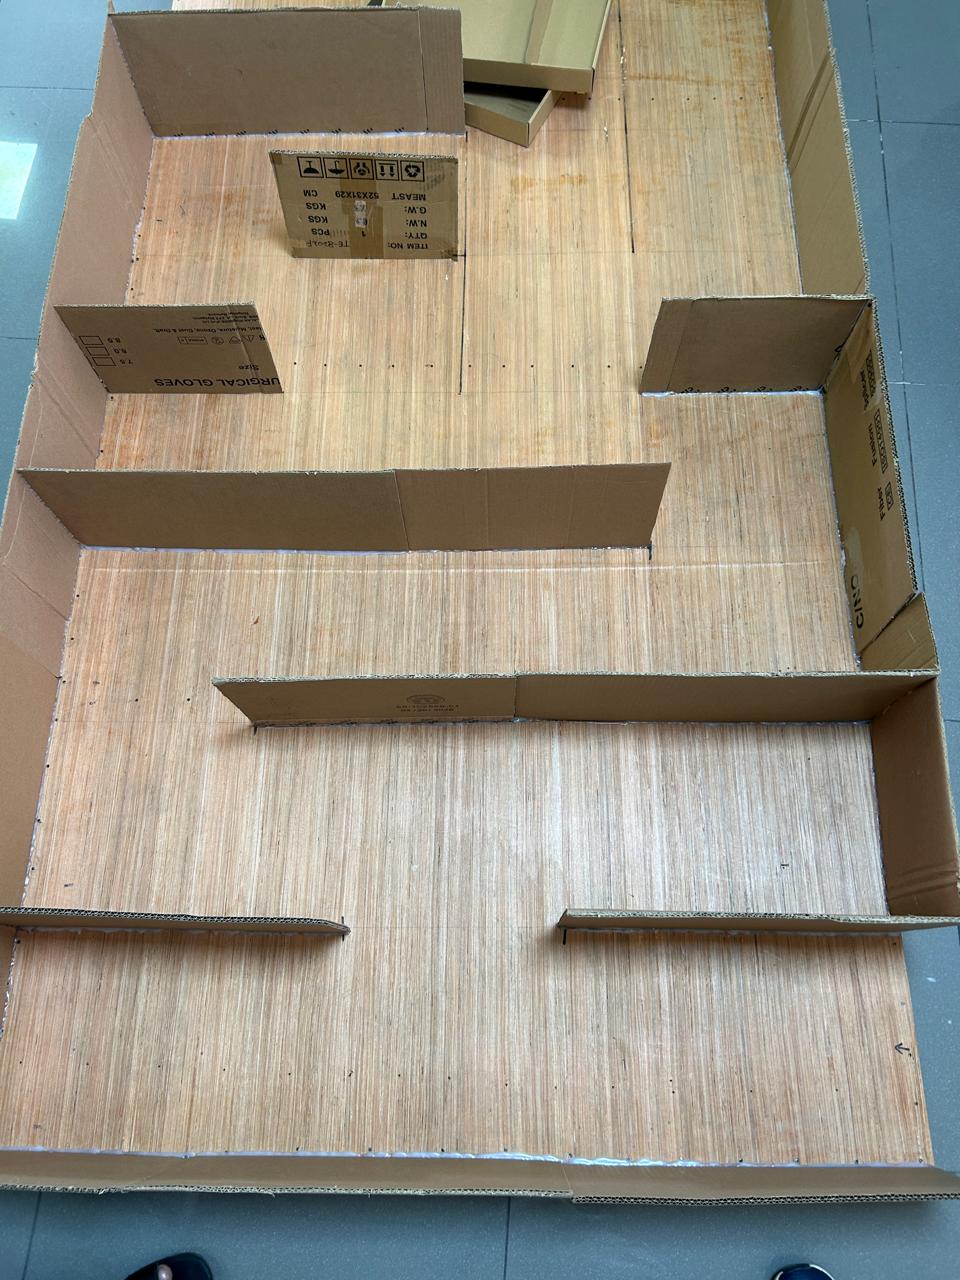
An autonomous maze-solving robot built from scratch using an ATmega328P microcontroller (Arduino Nano). This MicroMouse navigates through unknown mazes using the left-hand rule algorithm, combining ultrasonic sensor feedback with motor encoder data for precise movement control.
The robot features a dual feedback control system that fuses:
PID-based wall following using 3 HC-SR04 ultrasonic sensors
Encoder-based dead reckoning for accurate turns and straight-line tracking
Goal: Design and build a fully autonomous robot capable of navigating and solving standard maze configurations without human intervention.